




WGeorgezzzz
From perception and learning to action in the real world.
从感知与学习,到真实世界中的行动。
RoboParty · Selected work · Research & Engineering · Toolbox · Get in touch
A robotics developer at RoboParty. I work on robot learning, vision-language-action models, whole-body manipulation, simulation, and research tooling.
我的工作覆盖数据采集、模型训练、策略评估与机器人系统集成,关注 VLA、世界模型与 JEPA、全身动作生成,以及 Real2Sim。
我希望把模型、仿真和真实机器人连起来,也让研究过程能够被检查、复现和持续迭代。
| Robot learning | Simulation & data | Research engineering |
|---|---|---|
| VLA · World models · Whole-body skills | Real2Sim · Scene generation · Demonstration collection | Evaluation · Experiment lineage · AI agents |
将真实照片转成可编辑的三维场景,连接相机信息、部件建模、局部修订与仿真检查。
My public contributions include calibrated multi-view reconstruction, geometry and texture repair, and comparisons with preserved evaluation evidence.
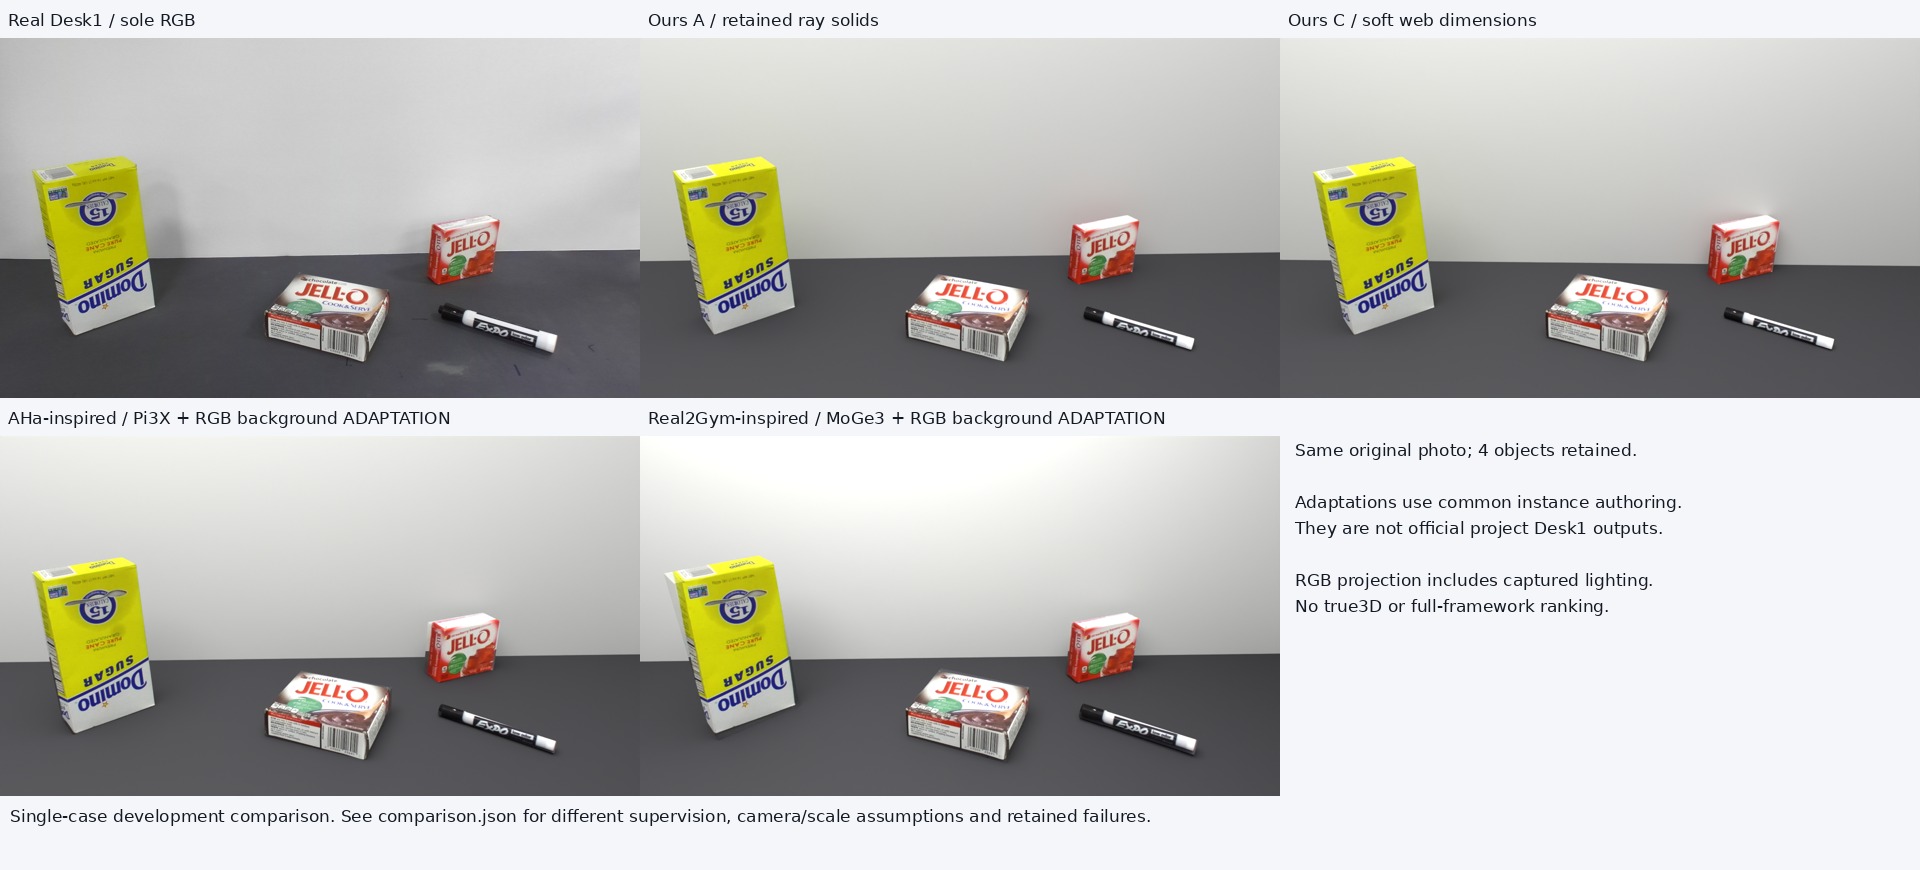
项目公开案例:Desk1 源图与重建对照;具体条件和评测范围见项目说明。
Repository ↗ · My contributions
Python Blender MuJoCo USD / GLB Camera calibration
把散落在代码、日志和报告里的研究过程,整理成可追溯的研究地图:问题、对照条件、运行记录,以及支撑结论的证据。
I contribute to research organization and run-level lineage visualization, making experimental relationships easier to inspect.
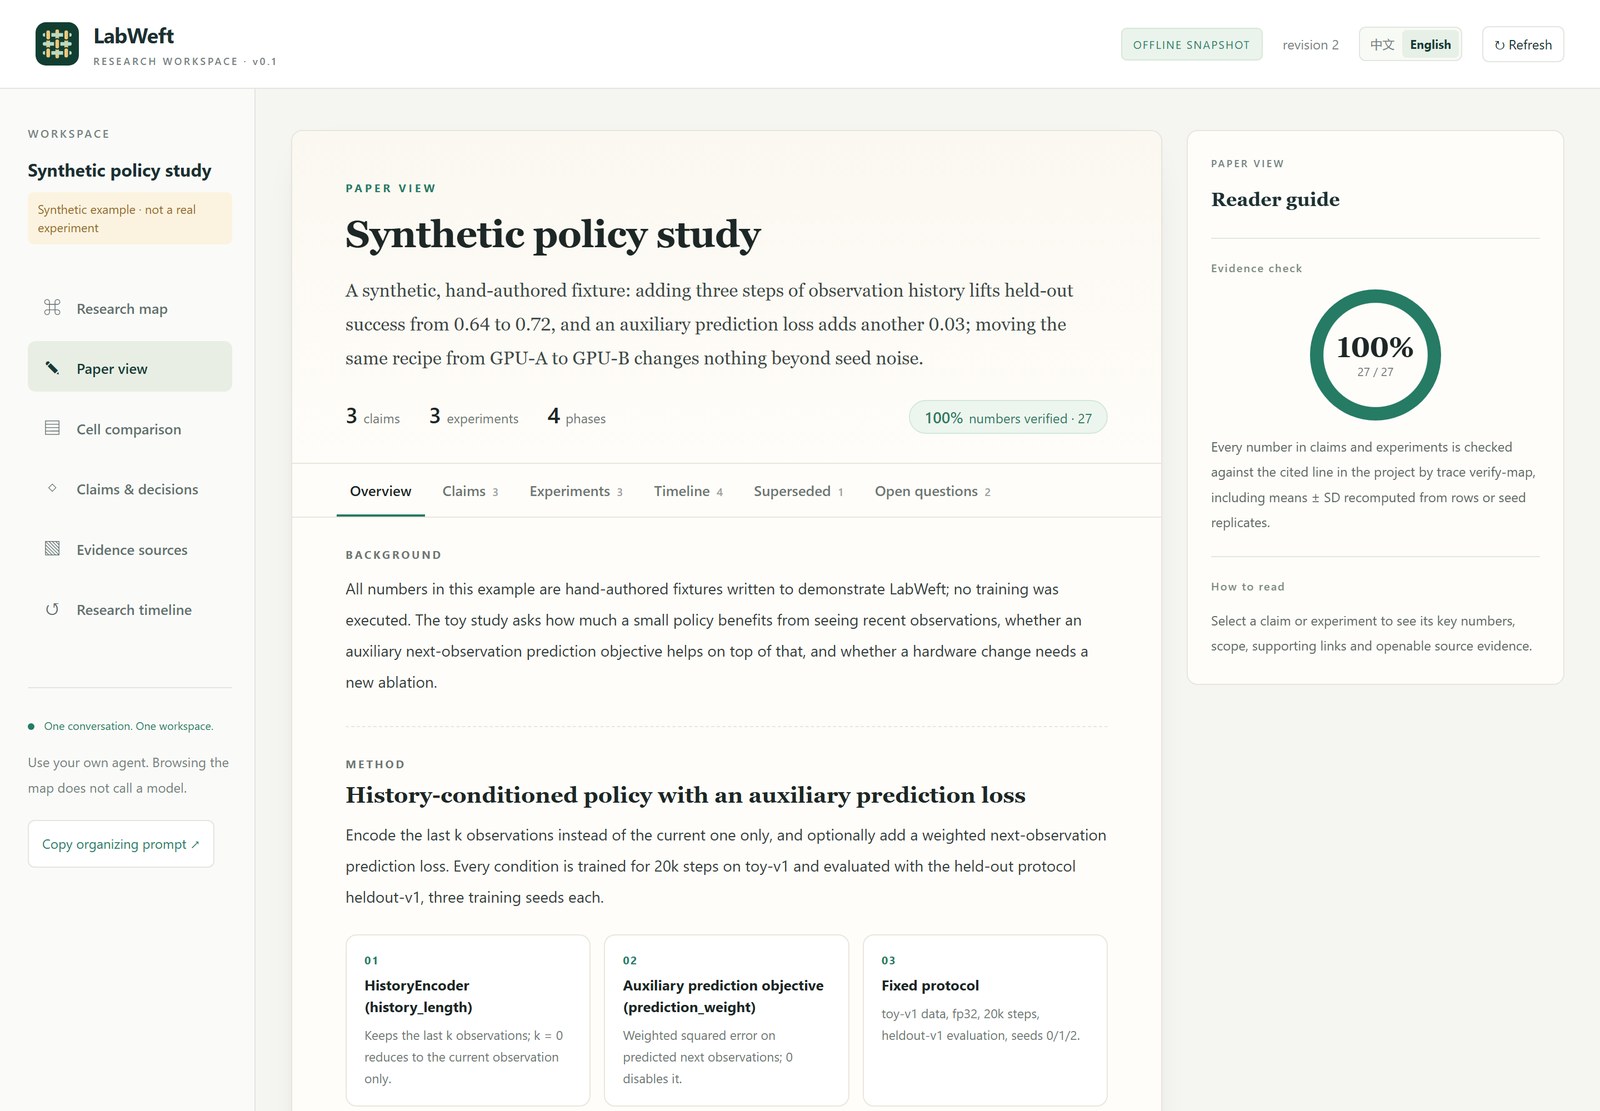
项目公开界面:研究问题、实验对照与来源关联。
Repository ↗ · My contribution
Python JavaScript Research tooling Experiment lineage
我参与开发的机器人系统、仿真平台与数据工具。非公开项目仅作文字介绍。
围绕人形与移动操作机器人构建统一任务执行和评测链路,推进 G1+Dex3、RP1、Luna 与 Piper 等平台的动作、场景和采集接口整合。工作涵盖导航、到站抓取、搬运、放置与释放,以及任务重置、评分、日志和回放;分别检查动作规划、接触、物体保持和最终任务结果。
Whole-body Control Manipulation Isaac Sim / Isaac Lab Task Evaluation
推进面向机器人任务的室内场景生成、家具资产组织与场景包标准化,将场景构建和机器人接入分离。工作涉及布局与装配、资产语义与材质、可交互部件、质量检查,以及与 RPArena 的接口,让操作任务、专家动作和数据采集复用一致的环境。
Scene Generation Asset Pipelines Articulated Objects Simulation
围绕 Piper 与 RoboTwin / ALOHA 操作任务,推进仿真示范采集、域随机化、多视角观测,以及图像、实测状态和动作的数据对齐。连接数据导出、质量检查与策略闭环评估,关注训练输入和部署接口的一致性,以及失败轨迹的保留与分析。
Demonstration Data Domain Randomization HDF5 Policy Evaluation
| Area | Tools & focus |
|---|---|
| Programming | Python · JavaScript |
| Robot learning | VLA · OpenVLA-OFT · RLinf · World models / JEPA |
| 3D & simulation | Isaac Sim / Isaac Lab · MuJoCo · Blender · RoboTwin / SAPIEN · USD / GLB |
| Data & systems | Demonstration collection · Domain randomization · HDF5 · FastAPI · MCP |
| Research workflows | Git / GitHub · AI coding agents · Reproducible evaluation |
Interested in robot learning, simulation, or research tooling? Let's compare notes.
欢迎交流机器人学习、具身智能与系统实践。
Public contact / 公开交流 ·
Explore RoboParty